## Wie ich helfen kann.
Lösungsdesign-Beratung
End-to-End-Architektur für Robotik- & KI-Systeme — vom Konzept und der Machbarkeit bis zu MVP und Feldeinsatz.
Robotik-Beratung
Autonome Plattformen, ROS-Stacks, Bewegungsplanung, Navigation und eingebettete Steuerungen für Außen- und Feldroboter.
KI-Beratung
Deep Learning, Reinforcement Learning und Entscheidungssysteme, zugeschnitten auf reale, datenarme Umgebungen.
Bildverarbeitung
Wahrnehmungs-Pipelines, semantische Segmentierung, SLAM und Visual Servoing für Robotik- und Industrieanwendungen.
Hardware-Startup-Advisory
Reviews von PCB- & Embedded-Design, Prototyping-Strategie, Forschungs-zu-Produkt-Transfer und Förderantragsplanung.
Software-Startup-Advisory
Technische Co-Founder-Unterstützung: Stack-Entscheidungen, MVP-Scoping, Recruiting und Engineering-Kultur für Early-Stage-Teams.
Vorträge für Events
Keynotes, Panels und Workshops zu Agrarrobotik, KI in der Landwirtschaft und der Markteinführung von Forschungsrobotern.
## Der Robotik-Operator.
Dr.-Ing. Alireza Ahmadi ist Gründer und CEO der DynamoBot GmbH (Dynamic Mobile Robotics) — tätig im Bereich der Agrarrobotik und KI — mit über 15 Jahren Erfahrung in Robotik-Forschung & -Entwicklung, eingebetteten Systemen und Präzisionslandwirtschaft.
Er hält einen B.Sc. in Elektronik & eingebetteten Schaltungen vom Tabriz Technical College (2013), einen M.Sc. in Geodätischer Ingenieurwissenschaft & Mobile Sensing vom IPB der Universität Bonn (2019) und einen Doktortitel vom Institut für Agrarrobotik & Engineering der Universität Bonn (2025), wo er BonnBot-I entwickelte — die präzise Unkrautmanagement-Plattform, die zur technologischen Grundlage von DynamoBot wurde.
Seine Arbeit wurde international ausgezeichnet — u. a. mit dem IROS 2022 Best Paper Award für Agrarrobotik (gesponsert von YANMAR, Kyoto), dem Transferpreis 2025 der Universität Bonn, dem Bayer Golden Ticket II für Crop-Science-Startups, einer Silbermedaille bei WorldSkills 2013 in Leipzig sowie mehreren Podiumsplätzen bei RoboCup. Er ist außerdem Gutachter für IEEE RA-L, JFR, ICRA, IROS und Computers & Electronics in Agriculture (Elsevier).
## Karriere-Log.
- Jan 2023 → now--founder
Gründer & CEO
DynamoBot GmbHBonn, DEGründung von DynamoBot (Dynamic Mobile Robotics). Aufbau einer Familie autonomer Roboter für Landwirtschaft und KI-gesteuerte Präzisionsjäten.
- 2020 – 2025--research
Doktorand & wissenschaftlicher Mitarbeiter
Agricultural Robotics & Engineering Institute, University of BonnBonn, DEMit Prof. Chris McCool: präzises Unkrautmanagement, Vision & Action, DL-basierte Maschinenvision, autonome bildbasierte Außennavigation und RL-basierte Multi-Agenten-Eingriffsplanung.
- Apr – May 2023--industry
F&E-Ingenieur (Teilzeit)
Farming Revolution GmbHGermanyNavigation auf Ackerflächen.
- 2019 – 2023--industry
F&E-Ingenieur (Teilzeit)
Escarda Technologies GmbHGermanyEntwurf & Implementierung der Escarda-Laserjät-Plattform: Jät-Action-Planer, Robotik-Systemdesign & Simulation, Embedded-Controller-Design und ROS-Integration.
- 2017 – 2018--research
Wissenschaftlicher Mitarbeiter
Photogrammetry & Robotics Lab (IPB), University of BonnBonn, DEMit Prof. Cyrill Stachniss: Navigation per Visual Servoing, RGB-D-Volumenkartierung & SLAM, Prototyp der AgriBot-Plattform und ein tragbares RedEdge-kompatibles Labeler-Gun für Agrar-Datensätze.
- 2017--research
Wissenschaftlicher Mitarbeiter (Teilzeit)
CAST Lab, University of TehranTehran, IRMitglied des Surena-4-Humanoid-Simulationsteams — Bewegungs- und Gangerzeugung für zweibeinige Humanoide.
- 2012 – 2017--industry
F&E-Ingenieur (Teilzeit)
PishRobotTehran, IREmbedded-Schaltkreis- & PCB-Design, C++/C#-Schnittstellen, Trainer für humanoide Roboter & ROS sowie Erweiterung von MBlock (Java) für die Produktlinie.
- 2013 – 2016--research
Wissenschaftlicher Mitarbeiter (Teilzeit)
Polytechnique University of Tehran (AUT)Tehran, IRHumanoid- und @Home-Service-Roboter-Teams: Embedded-Controller, Gang- & Aktionserzeugung für Bipeds, UGV-Bewegungssteuerung und Bildungsroboter-Plattformen.
- 2013 – 2015--teaching
Laborleiter — Organisator des nationalen Skills-Wettbewerbs
Technical & Vocational Organization of IranIranDozent für mobile Robotik, eingebettete Controller (AVR/ARM) und Programmierung (Python, C++); Organisator des nationalen Skills-Wettbewerbs für mobile Robotik.
## Ausbildung.
Promotion, Präzises Unkrautmanagement — Robotik & Robotervision
M.Sc., Geodätische Ingenieurwissenschaft & Mobile Sensing
B.Sc., Elektronik & eingebettete Schaltungen
## Projekte.
DynamoBot
Biodiversitäts-bewusster Jät-Anhänger.
PhenoRob — BonnBot
Roboter für präzises Unkrautmanagement.
Escarda
Eingriffs- & Wahrnehmungskopf für laserbasiertes Jäten.
AgriBot · DynaMap
Volumetrische Kartierung verformbarer Objekte.
Surena 4
Humanoid-Simulationsteam.
Sepanda @Home
Plattform für Haushalts-Serviceroboter.
AUTMan Humanoid
Teen-Size-Humanoid für RoboCup.
## Auszeichnungen.
- [2025]Transferpreis — Universität Bonn, Deutschland.
- [2025]Bayer Golden Ticket II — Crop-Science- & Ag-Tech-Startups (Bayer × HTGF), Bonn.
- [2025]Ignition digiHub Pre-Seed Startup-Förderung — PTJ & Land NRW, Deutschland.
- [2024]Prototyping-Förderung (Runden 1 & 2) — PhenoRob / DFG, für die DynamoBot-Ausgründung.
- [2023]Prototyping-Förderung — enaCom Transfer Center, Universität Bonn (DynamoBot-Ausgründung).
- [2022]IROS Best Paper Award für Agrarrobotik (gesponsert von YANMAR) — Kyoto, Japan.
- [2015]Dritter Platz — RoboCup, Humanoid Teen-Size League. Hefei, China.
- [2015]Zweiter Platz — RoboCup Technical Challenge, Humanoid Teen-Size. Hefei, China.
- [2014]Bester Technologe — Nationale Elite-Stiftung des Iran.
- [2013]Silbermedaille (2. Platz) — 42. WorldSkills International, Mobile Robotik. Leipzig.
- [2013]Goldmedaille — Bester des Landes, 42. WorldSkills. Leipzig.
- [2012]Erster Platz — 13. Iran TVTO Nationaler Skills-Wettbewerb, Mobile Robotik. Karaj.
- [2012]Mitglied — Iranische Nationale Elite-Stiftung.
## Dienst & Lehre.
Gutachter — IEEE Robotics & Automation Society
Gutachter für RA-L, Journal of Field Robotics (JFR), Computers & Electronics in Agriculture (Elsevier), ICRA und IROS.
Lehre — Universität Bonn
- › MSR-Projekt — Mobile Sensing & Robotik (autonome Navigation, Farm-Monitoring & Planung)
- › Betreuung von B.Sc.-Abschlussarbeiten — mechanische Jätwerkzeuge für mobile Roboter
## Ausgewählte Publikationen.
## GitHub-Aktivität.
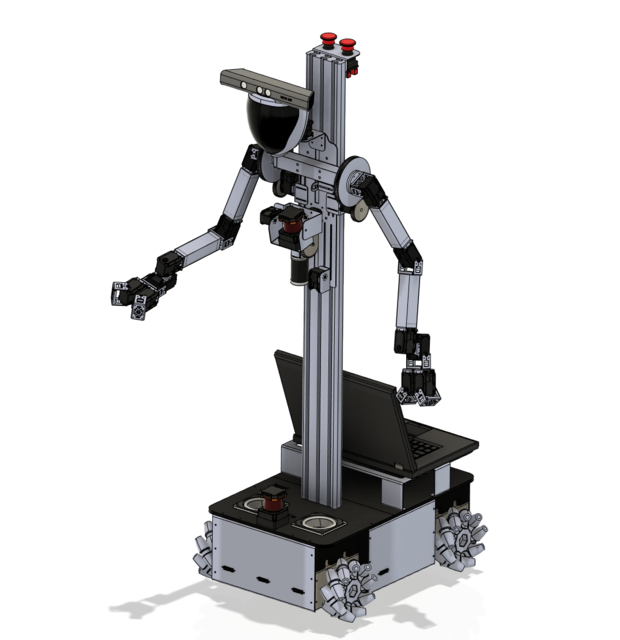
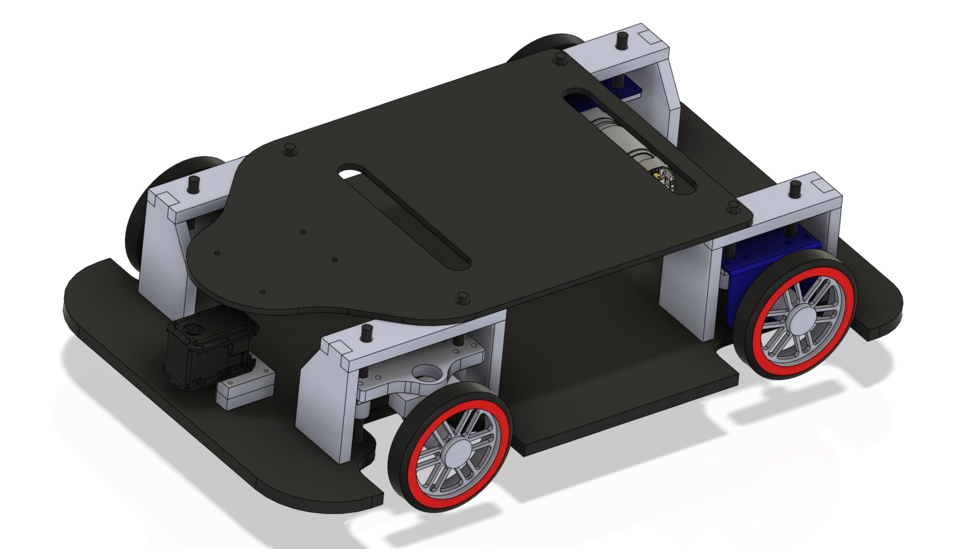
## CAD & Mechanischer Entwurf.
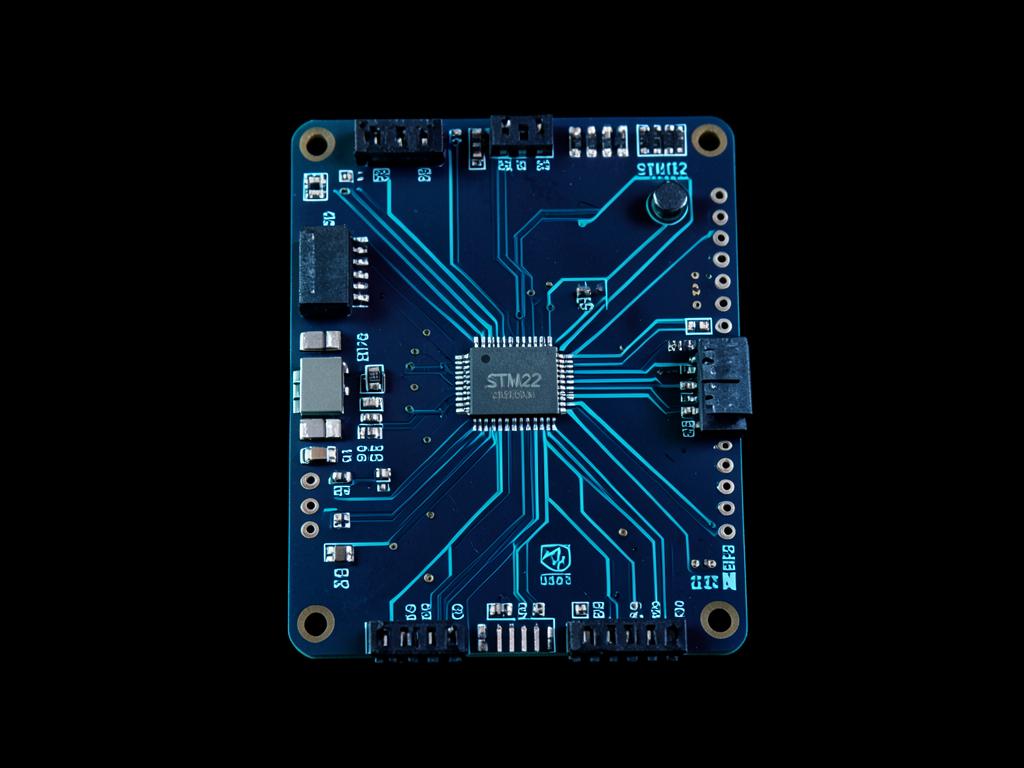
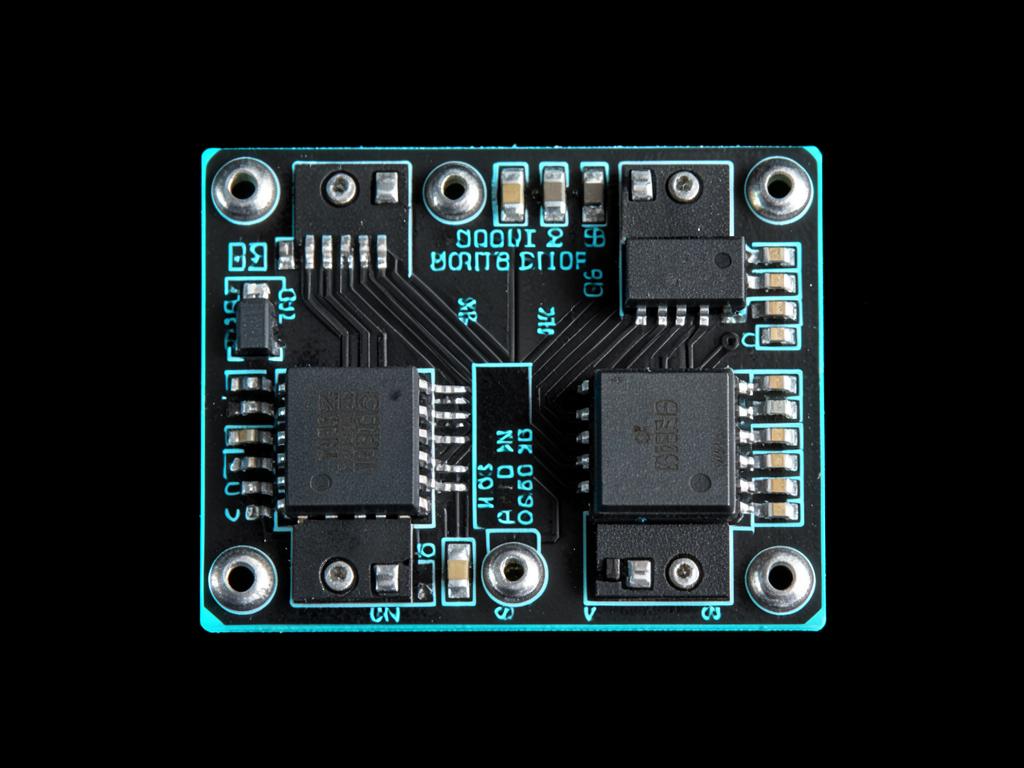
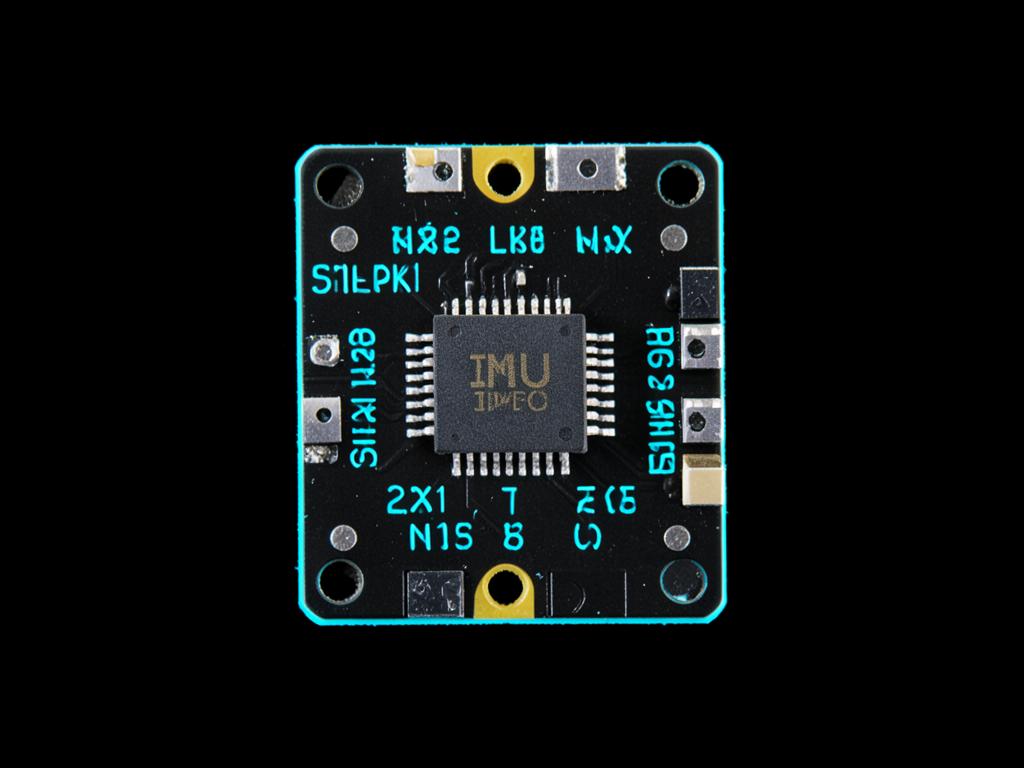
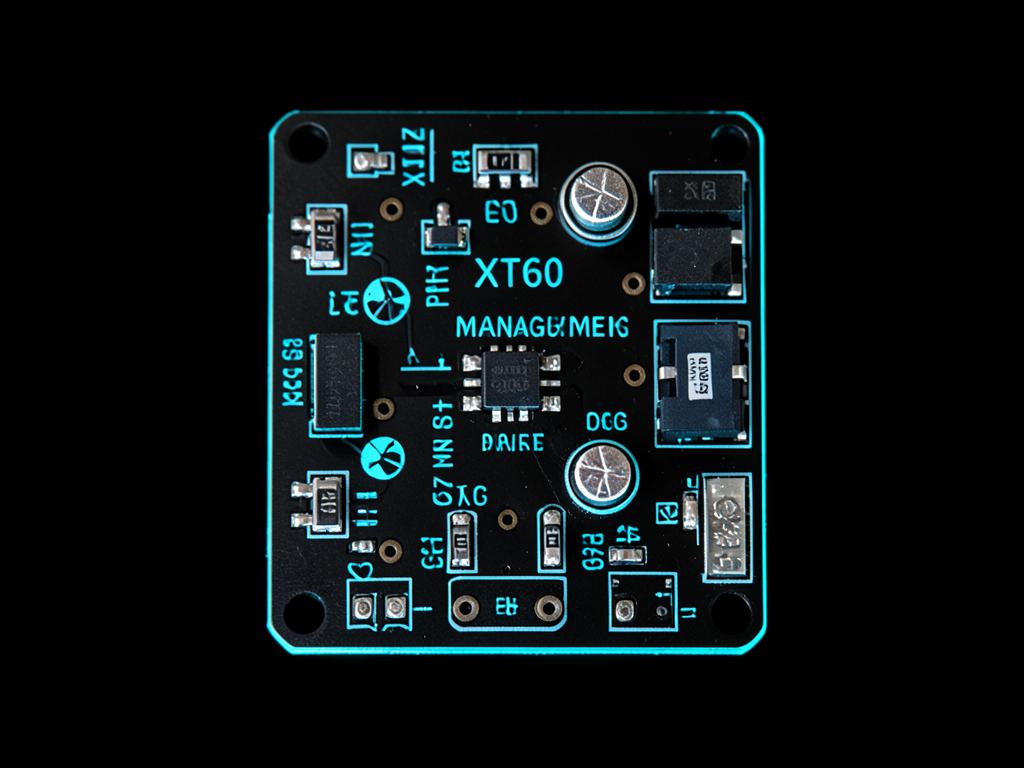
## Elektronik & Leiterplatten.
## Practical Robotics — Videos.



## Lass uns über Roboter sprechen.
{
  "address":   "Nussallee 5, 53115 Bonn, DE",
  "linkedin":  "linkedin.com/in/alirezaelecat",
  "github":    "github.com/alirezaahmadi",
  "youtube":   "@DynamoBotGMBH",
  "company":   "dynamobot.de",
  "languages": "Persian · Azeri · English · Deutsch (B2)"
}